Ovis_3D_Position_Orientation_TaitBryan_Get()
Abstract
Obtains a Tait-Bryan rotation based on a specified position and orientation.
Syntax
Ovis_3D_Position_Orientation_TaittBryan_Get (pos, pitch, yaw, roll, rot_ptr)
| Argument | Type | Description |
|---|---|---|
pos |
OvisT_3D_Position |
Position of reference, in geocentric coordinates |
pitch |
double |
Pitch, in degrees |
yaw |
double |
Yaw, in degrees |
roll |
double |
Roll, in degrees |
rot_ptr |
OvisT_TaitBryan * |
Pointer to rotation relative to Earth's referential |
Return Type
OvisT_Compcode
OvisC_Compcode_Success if the rotation can be computed; OvisC_Compcode_Failure otherwise.
Header
ovis_decoration.h
Details
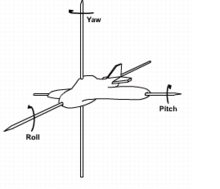
This function computes the Tait-Bryan set of rotations with respect to the earth's geocentric coordinate system, based on the pitch, yaw, and roll values in the local coordinate system at the specified position.
Figure 10: Pitch, Yaw, and Roll
Example
OvisT_3D_Position     pos;
OvisT_3D_Sphere     * disk;
OvisT_3D_TaitBryan    rot;

/* Place a flat disk hovering over a location */
Ovis_3D_Position_Geocentric_Set (&pos, 2015649.973, -456789.123, 750.58);
disk = Ovis_Decoration_3D_Sphere_Create (pos, 10, 0, 10,
	prg_color_from_string ("white"), OvisC_True, OPC_NIL, OPC_NIL, OPC_NIL);
Ovis_3D_Position_Orientation_TaitBryan_Get (pos, 0, 0, 0, &rot);
Ovis_3D_Polygon_Rotation_Set (disk, rot);
Errors
- Return address for rotation is NIL.
- 'Decoration' 3D position is not supported.
Reference
- Use the function
Ovis_3D_Polygon_Rotation_Set()to orient a 3D polygon using the computed Tait-Bryan.